arXiv 2026
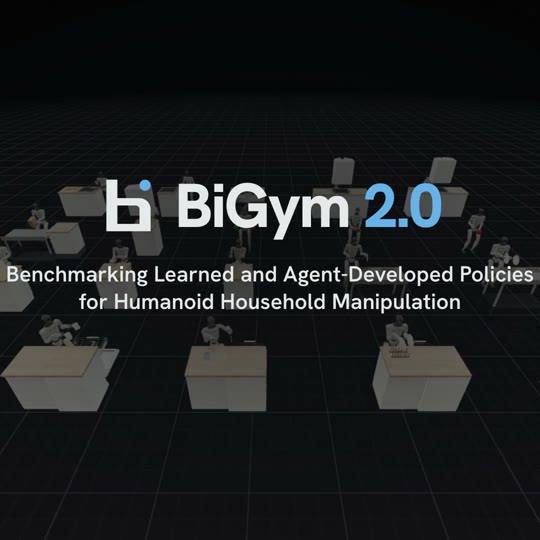
A household loco-manipulation benchmark for the Unitree G1: 20 tasks with native VR demos under closed-loop whole-body control, evaluating VLA fine-tuning, imitation learning, demo-driven RL and coding agents through one interface.
I am a CS Ph.D. student at Imperial College London and a member of the Safe Whole-body Intelligent Robotics Lab (SWIRL), advised by Prof. Stephen James. My research focuses on foundation models in robot learning. I also enjoy running RL on myself in the real world, where rewards are sparse and there is no reset button :)
My research focuses on enabling intelligent agents, particularly humanoid robots, to perceive, reason, and physically interact with the world.
arXiv 2026
A household loco-manipulation benchmark for the Unitree G1: 20 tasks with native VR demos under closed-loop whole-body control, evaluating VLA fine-tuning, imitation learning, demo-driven RL and coding agents through one interface.
ICRA 2026
An end-to-end VLM for Vision-Language Navigation that fuses topology-aware spatial reasoning with global action decisions, staying competitive on R2R at just 0.5B parameters.
I enjoy the craft of bringing ideas to life with code, especially through front-end development. I frequently share my thoughts and projects on my blog.
Teaching (Undergraduate TA):
Hobbies: Bouldering, swimming, badminton, tennis, and FPS games (CS2, Overwatch, etc.). I was a Top 500 player in Overwatch 2!
Email: mvoc.l3iamg@p201gnnahzkess3j
Community: If you have ADHD and need someone to talk to, I'm happy to schedule a 30-minute chat every month. Feel free to reach out.